The seven classes
A sovereign-estate charging infrastructure serves seven distinct classes of consumer. Designing for one class without naming the others produces an installation that fails the moment the household’s actual fleet arrives.
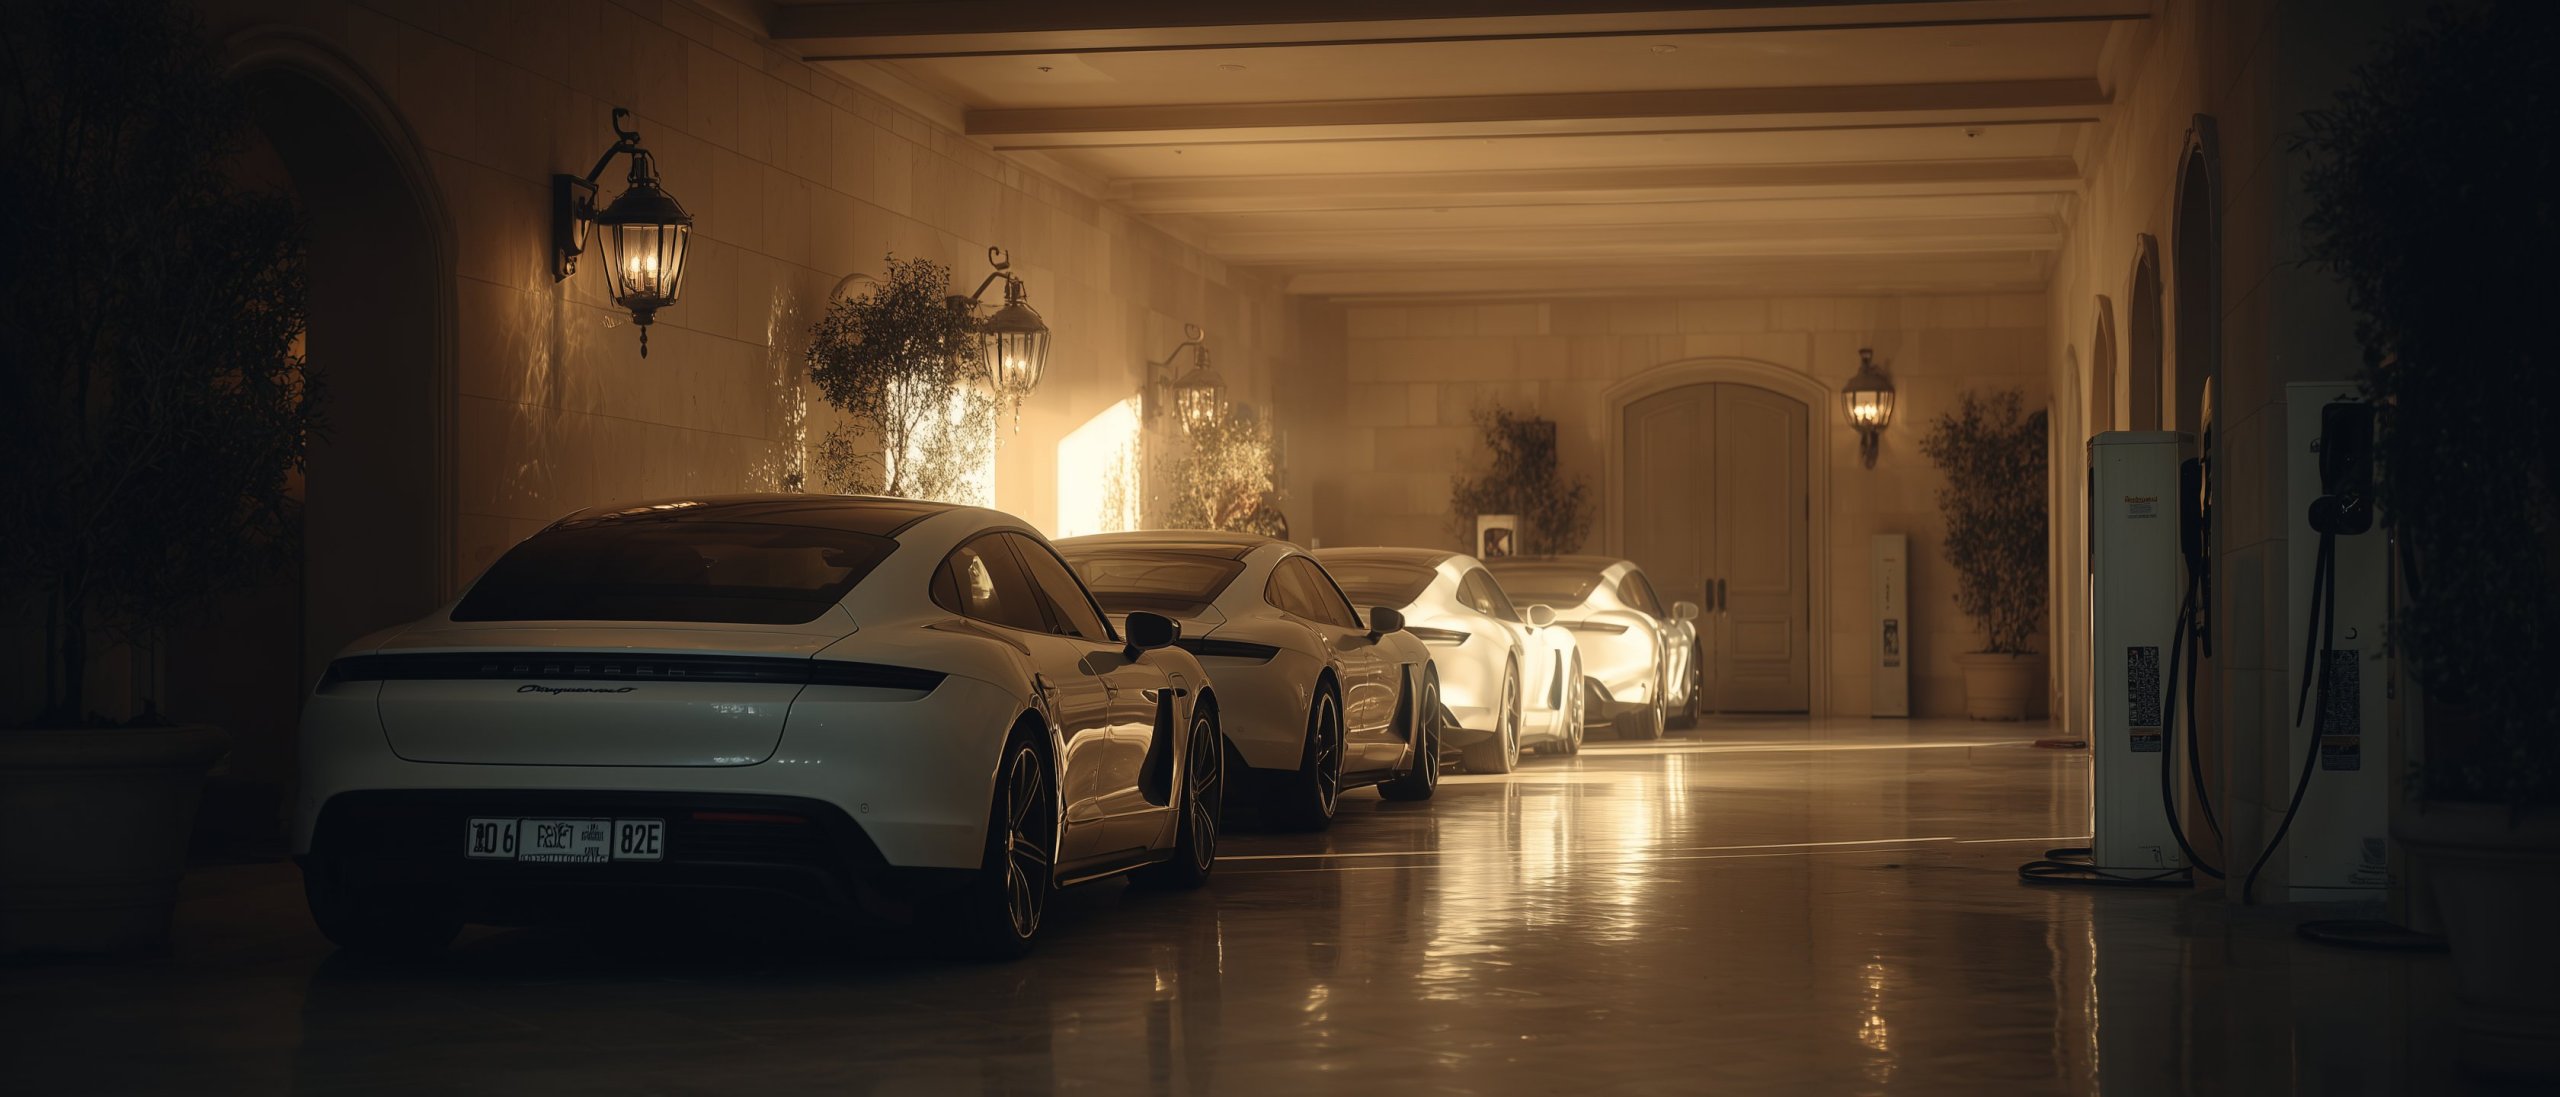
Daily-driver EVs. The household’s standard cars — sedans, SUVs, performance vehicles in regular use. Pack sizes 75–120 kWh, daily energy 30–60 kWh, charged overnight at Level 2 (11 or 19 kW). One connector per parking position rather than shared connectors. The cost difference is modest; the operational difference is the household never thinking about charger availability.
Hypercars. The high-performance electric vehicles in the collection — Rimac Nevera, Lotus Evija, Pininfarina Battista, Aspark Owl, and successors. Packs of 100–130 kWh, capable of accepting 350 kW or higher DC fast-charging, but typically driven sparingly and stored carefully. The infrastructure requirement is DC fast charging on demand when the car is going out, and gentle Level 2 for routine pack maintenance and the slow top-ups that preserve cell life. Readiness when needed, not continuous draw.
Autonomous fleet vehicles. The vehicles in continuous or near-continuous operation supporting the household and the estate’s movements. Less garage time, more total miles, charging that fits between operational windows. Fast reliable replenishment during scheduled returns, with dispatch logic coordinating which vehicle charges when against the household’s anticipated needs.
eVTOL aircraft. The category arriving now. As of mid-2026, Joby Aviation is the FAA-certification leader (Stage 4 cleared March 2026, Type Certificate expected late 2026), with paying-passenger service already operating from Skyports at Dubai International Airport. Archer and Beta are behind that on the US certification track. Packs of 150–250+ kWh, with charge requirements measured against operational turnaround — the aircraft is unusable while charging, so the infrastructure has to recharge meaningfully in 30 minutes or less. This is megawatt-class charging for short windows, a fundamentally different infrastructure category from vehicle charging.
Marine vessels. On estates with water access. Electric tenders and small craft at 30–100 kW shore power; larger electric yachts at 200–500 kW for sustained recharging. Marine infrastructure is separate from the garage both physically (dockside) and electrically (dedicated runs from the equipment building, typically with its own subpanel and disconnect).
Humanoids. Working humanoids in the household — Optimus, Figure, Apptronik, and their successors. Battery sizes 2–5 kWh per unit, charge cycles every two to four hours of active operation. Multiple units in continuous service produce a continuous-cycling load: small instantaneous draw, meaningful accumulation. Dedicated docks in back-of-house areas, integrated with the units’ own task scheduling.
Robotics and autonomous equipment. The long tail — autonomous mowers, pool robots, perimeter drones, autonomous service equipment, single-purpose autonomous tools that populate a serious estate. Individual draws under 1 kW per device; the population is growing and the cumulative contribution to base load is becoming non-trivial. Distributed charging docks at the locations these devices operate from, not a centralized facility.
Estates that design against only the daily-driver pattern find within a few years that the fleet has outgrown what was installed — the hypercar has nowhere to fast-charge, the autonomous vehicles compete with daily drivers for connectors, the addition of an eVTOL or a humanoid complement requires an electrical upgrade rather than a connection. Design against the full set from the start, and the infrastructure absorbs growth without being rebuilt.
Charging speeds
Four speeds matter, each tied to specific classes above. Level 1 (120V AC, ~1.4 kW) is incidental — useful for trickle charging vehicles in storage. Level 2 (240V AC, 7–19 kW) is the workhorse: every daily-driver and autonomous-vehicle parking position, hypercars between drives, shore power for smaller vessels. DC fast charging (50–350 kW) is a different infrastructure category — substantial electrical service, dedicated equipment, integration with the microgrid’s peak-power architecture, typically one or two dedicated bays. Ultra-fast and megawatt charging (350 kW+, with the CharIN MCS standard targeting 1.25 MW) is what eVTOL turnaround and the largest electric yachts require: industrial-class equipment with utility-feed-scale service.
The peak-power problem
The central engineering challenge is what happens when fast charging is in use. A 350 kW DC fast charger pulling for 20 minutes during evening hours — the household has returned, the hypercar needs to be ready for tomorrow morning — is a substantial event. The microgrid has to absorb this draw without compromising the rest of the estate’s operation, and how it does so is what separates a sovereign-estate installation from a luxury garage with chargers.
Two approaches handle the peak.
Grid-supplemented. The macro grid carries the peak; storage smooths the very-short-term spikes the inverter cannot immediately follow. Acceptable on estates with utility service rated for the peaks, but it surrenders some of the sovereignty posture the rest of the estate is built on. The grid sees what the estate is doing, the utility’s demand charges apply (often substantially), and islanded readiness is compromised during the event.
Storage-buffered. The estate’s storage system carries the peak entirely; the grid sees only a smoothed, baseline draw. The 350 kW hypercar pull comes from storage, which then recharges from grid or solar at a steady, much lower rate over the following hours. This is the sovereign-estate answer. It requires storage capacity sized to absorb the peak, discharge rates the chemistry supports, and dispatch logic that coordinates the charging events against storage state. The macro grid never sees the peak; the islanded readiness remains intact.
The architectural consequence is that storage sizing has to account for the fast-charging peak buffer, not just the daily cycle and the islanded endurance. This is one of the most common storage-sizing errors in early sovereign-estate builds: the storage is sized for the residence and the islanded scenario but not for the fast-charging events, and the system surprises the household the first time the hypercar is fast-charged and the lights dim or a grid demand charge appears on the bill.
Vehicle-to-everything
The traditional view of charging is one-directional: the residence supplies, the vehicle stores. Modern EVs increasingly discharge the other way — back into the residence, the grid, or specific loads. V2X has three modes that matter on a sovereign estate.
V2L (vehicle-to-load). The vehicle powers specific equipment directly, through AC outlets on the vehicle or dedicated discharge connections. Useful for remote-property equipment, emergency operation of specific loads when residential storage is exhausted, and the working scenarios the household actually uses (tools at a worksite, an event on a remote part of the property). Supported in some form by most modern EVs; useful but not architecturally consequential.
V2H (vehicle-to-home). The vehicle’s pack functions as supplementary storage for the residence — discharging into the household’s electrical system to supplement the BESS during peaks, extend islanded operation during outages, or contribute to dispatch optimization. This is the architecturally consequential mode. A fleet routinely connected to V2H-capable chargers adds substantial effective storage to the microgrid: a 100 kWh vehicle pack is, when available, a meaningful addition to a 500 kWh BESS.
V2G (vehicle-to-grid). The vehicle participates in grid-services markets, discharging during peak grid demand in exchange for revenue or grid credits. Economically interesting on estates whose utility supports V2G; rarely the primary reason to adopt V2X at sovereign-estate scale, since the operational-sovereignty considerations outweigh the modest economic return.
The architectural decision is whether the infrastructure supports V2X and at what scale. It affects connector selection (V2X-capable hardware is a growing subset of available chargers), wiring (bidirectional power flow has implications for protection and grounding), and dispatch logic (which vehicles are eligible for V2H, at what state-of-charge thresholds, with what household priority overrides). On a fully integrated sovereign estate, V2X is a deliberate addition to storage capability, not an afterthought.
Wireless and inductive
Wireless charging across an air gap is moving from demonstration into specific applications. Not yet competitive with cable on efficiency or power level for primary vehicle charging, but viable for two cases that matter on a sovereign estate: autonomous fleet bays where the vehicle self-parks over an in-floor inductive pad (the 5–10% efficiency penalty is acceptable for the operational benefit of not requiring physical connector engagement), and humanoid docking where contactless approaches reduce mechanical wear and improve positioning tolerance. Cable charging remains primary for hypercar fast-charging and eVTOL turnaround. The discipline is to reserve the option in the build (in-floor electrical service to autonomous bays, contactless dock provisions at humanoid stations) without forcing it where cable is still superior.
The decisions that matter
Five decisions in a sovereign-estate charging infrastructure have consequences worth surfacing at the design level.
Sizing against the future fleet. The fleet of 2026 is not the fleet of 2031. An estate designed for three EVs and a hypercar today often has six EVs, two hypercars, a fleet of autonomous vehicles, an eVTOL, and three humanoids by the time it is half a decade old. Sizing electrical service, panel capacity, and conduit pathways for the projected mature fleet is the difference between an installation that grows gracefully and one that requires service upgrades repeatedly.
Connector standards. Ground-vehicle DC fast charging has standardized substantially on NACS (Tesla-originated, now the US de facto standard adopted across most OEMs) and CCS, with J1772 the Level 2 default. eVTOL and large-vessel megawatt charging is converging on CharIN MCS. Marine, humanoid, and robotics charging use separate connector ecosystems. The infrastructure should support the standards the actual fleet uses, with adapter availability where needed.
V2X readiness. Whether to support V2X at design time has architectural implications. The default for new sovereign-estate builds is yes — the technology is mature enough, the storage value is real, and the additional cost at design time is modest compared to retrofit.
Distributed versus centralized. Some estates concentrate charging in a single main garage; others distribute it across multiple garages, marine infrastructure, the eVTOL pad, humanoid stations, and robotics docks. Distributed matches actual fleet topology better and reduces single-point failures, at the cost of more conduit runs and more panel capacity at the perimeter. Most sovereign estates are distributed by topology necessity, but the deliberate decision is worth making rather than letting topology decide.
Integration with the operations console. Every charging event — vehicle, eVTOL, marine, humanoid, robotics — produces telemetry the operations console can display and the digital twin can record. The integration of charging into the operational substrate is what lets the household see fleet readiness at a glance, lets EstateAI coordinate charging against the day’s anticipated needs, and lets the long record of charging behavior inform future capacity decisions. Charging outside the substrate is charging the operation does not really see.
EstateOps
Charging is where the energy system meets the mobility fleet day by day — instrumented through the substrate, dispatched by EstateAI against the household’s anticipated needs, displayed on the operations console as fleet readiness. Done well, the infrastructure is invisible to the family: it just produces the readiness the estate’s mobility depends on.